About Me
Welcome to my website! I'm a Ph.D. candidate in AI Robotics at MIT CSAIL, advised by Leslie Kaelbling and Tomás Lozano-Pérez.
My research focuses on embodied reasoning and lifelong learning agents. I work toward robots that accumulate reusable knowledge and skills through experience, then adapt and compose them to solve new tasks.
I study how embodied agents can turn experience into knowledge and skills that support increasingly complex behavior. How should a robot represent and remember what it has learned? How can it combine familiar capabilities to solve unfamiliar problems, or reason and act over long horizons?
My research approaches these questions by connecting top-down reasoning and planning with bottom-up learning, spanning models, memory, skills, and programs. The broader goal is lifelong learning: robots that learn through play, learn from humans, and improve through practice. Ultimately, I aim to build general-purpose robots that continually expand their capabilities by adapting and reusing what they learn across tasks, objects, and environments.
Recent News
Publication: Our paper Generalized Planning Interfaces for Agentic Robotics was accepted at the CoRL 2026 Workshop on Agentic Robotics!
Publication: Our paper Rational Inverse Reasoning was accepted at the CoRL 2026 LEAP Workshop!
Publication: Our paper KeyFlow was accepted at the CoRL 2026 Learn@Deploy Workshop!
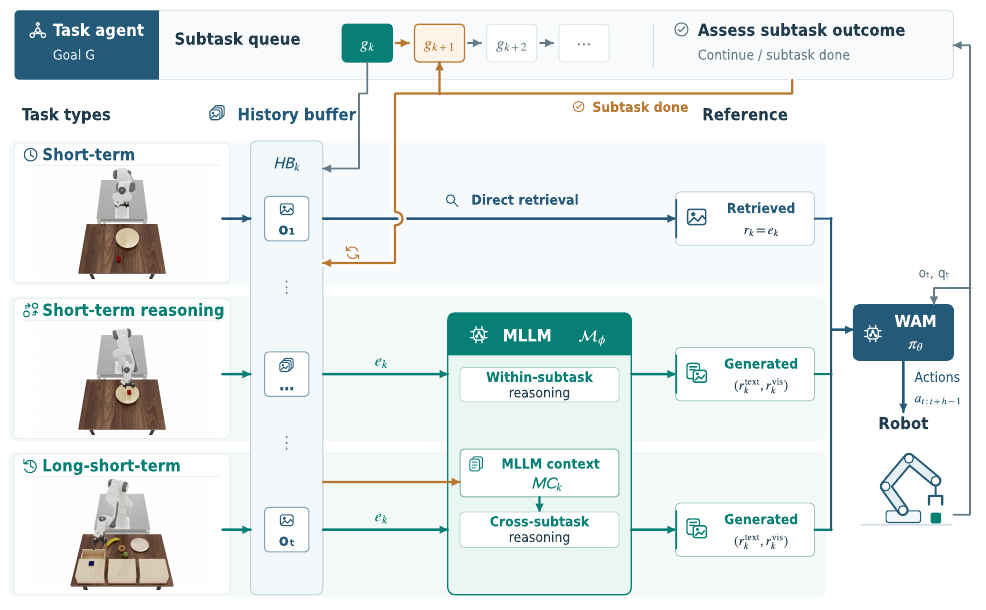
Publication: Our paper GEMA was accepted at the CoRL 2026 Workshop on Memory for Robot Foundation Models!
News: I'm helping organize the CoRL 2026 workshop on Compositional Generalization for Real-World Robot Learning!
News: I've begun building my online interactive robotics resource! Take a look at the outlines of its first two series, on motion planning and reinforcement learning, and stay tuned for the chapters in the coming months.
Publication: Our newest work, on "Rational Inverse Reasoning" is now available on arXiv!
Talk: Presented our work on "Hierarchical Vision-Language Planning for Multi-Step Humanoid Manipulation" at RSS 2025 Workshop on Robot Planning in the Era of Foundation Models!
News: Excited to begin my PhD journey in the Computer Science and Artificial Intelligence Laboratory (CSAIL) at MIT!
Selected Research
Recent Blog Posts
- Hello, World — Thu Sep 04 2025
Mentoring
Current students
Yifan KangUROP
Agentic Learning from Demonstrations
Devin YangUROP
World Models and Latent Space Planning
Past students
Katherine LinMEng
Skill Learning and Composition
Evan KimUROP
Programmatic World Models (ARC-AGI-3)
If you are interested in mentoring or research opportunities, please reach out.