Metal2Humanoid
MIT IAP course · 4–29 Jan 2027 · MIT, Cambridge, MA · Taught by Ben Zandonati, Willie McClinton, Seth Robles, James Kim
Building a Humanoid Robot from the Ground Up
A hands-on introduction to humanoid robotics, tracing the path from motors and actuators to coordinated motion and learned behavior. Over four weeks, students work in teams to assemble and test components of an open-source humanoid based on Berkeley Humanoid Lite. Topics include motors, transmissions, encoders, robot kinematics, feedback control, simulation, reinforcement learning, and transferring policies to physical hardware.
Each week combines two lectures, a guided hardware lab, and a scaffolded Python assignment. Projects progress from actuator position control to limb motion, simulated locomotion, and system integration, culminating in a team demonstration and brief technical report. Hardware components and software scaffolds are prepared in advance.
What we’re building
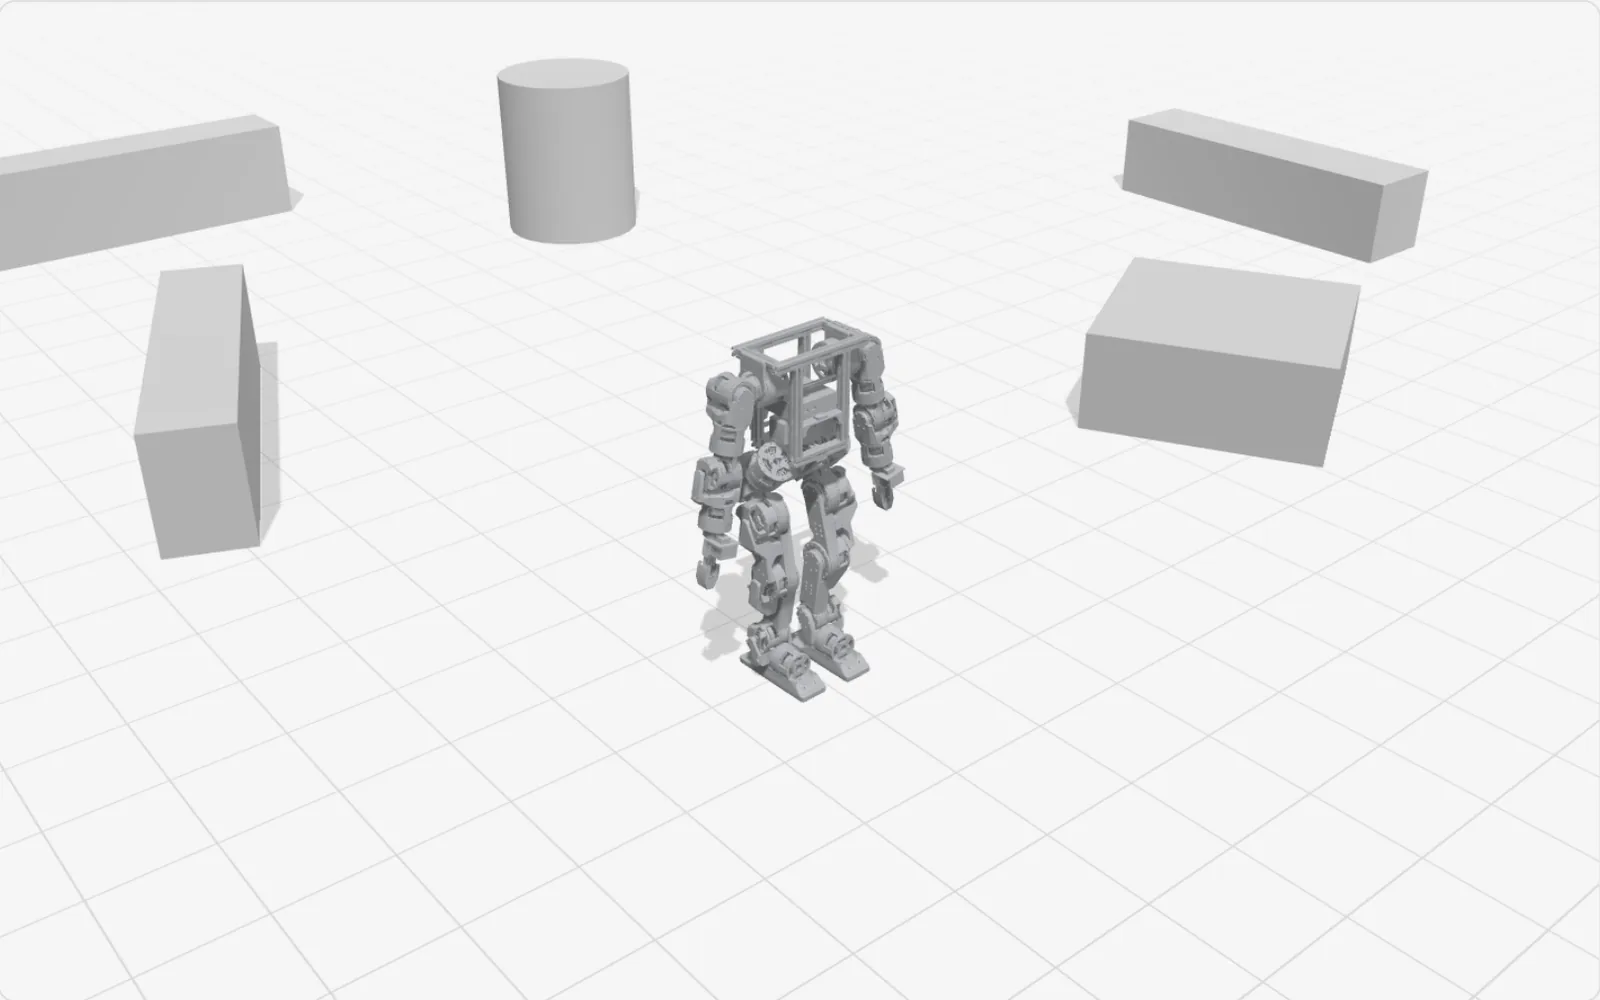
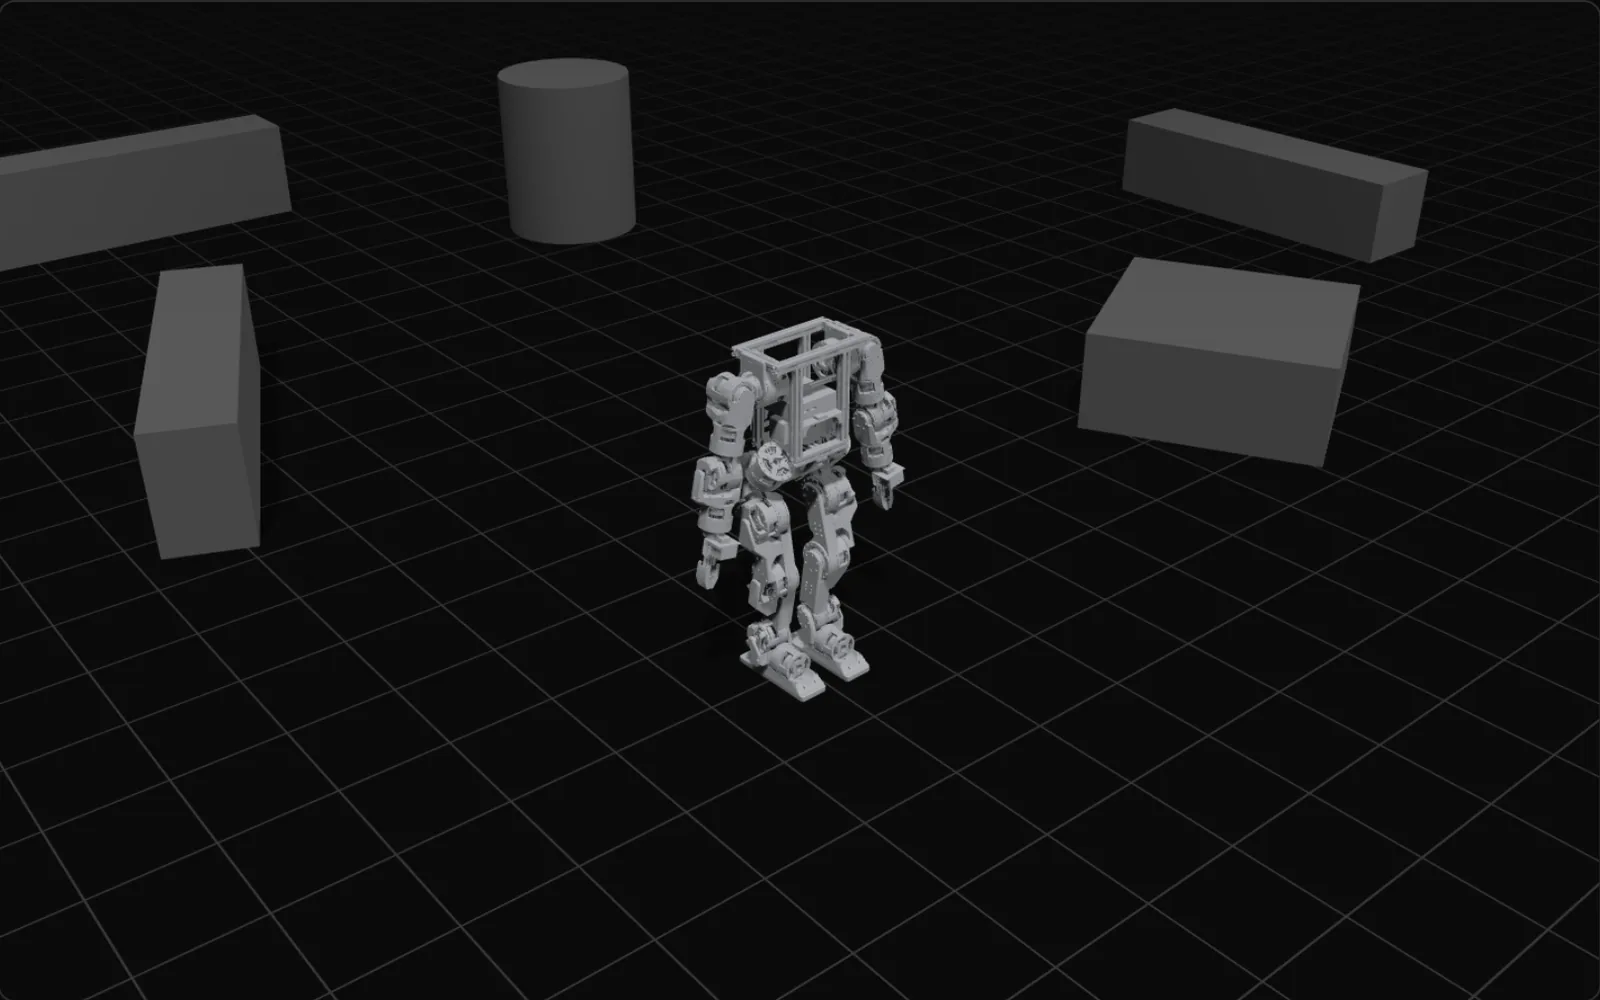
The robot the course builds is a version of the Berkeley Humanoid Lite, an open-source humanoid made from 3D-printed parts and off-the-shelf motors. Here it is in simulation, in your browser, walking with an RL-trained policy — the same kind of controller students train in week 3.
Teaching team
- Ben Zandonati: instructor, MIT EECS
- Willie McClinton: co-instructor, curriculum and robotics instruction
- Seth Robles: co-instructor and undergraduate laboratory teaching assistant
- James Kim: co-instructor and hardware laboratory instructor
Faculty sponsor: Tomás Lozano-Pérez, MIT EECS.
Who it’s for
Open to undergraduate and graduate students. An introduction to computer science or robotics, or equivalent experience, is expected. Assignments use Python. No prior hardware assembly, control theory, or machine learning experience is required.
Learning objectives
- Explain how motors, transmissions, encoders, and feedback control produce controlled joint motion.
- Model robot limbs and implement basic end-effector motion in simulation.
- Train and evaluate a scaffolded locomotion policy and identify simulation-to-reality challenges.
- Integrate and test robot subsystems, document results, and demonstrate coordinated behavior.
Schedule
Lectures are on Tuesdays and Thursdays, 1:00–2:30 p.m., from 5 to 28 January; hardware labs on Fridays, 1:00–2:30 p.m., from 8 to 29 January. There’s an optional office hour each week. Rooms are to be confirmed.
Open a week for its lectures, lab and assignment.
- Lectures: Motor fundamentals; Transmissions, encoders, and feedback control.
- Lab: assemble and test an actuator module from prepared components.
- Assignment: implement and evaluate motor position control.
- Lectures: Robot modeling and forward kinematics; Inverse kinematics and trajectory generation.
- Lab: assemble actuators into a limb and validate joint motion.
- Assignment: implement end-effector motion control in simulation.
- Lectures: Reinforcement learning for locomotion; Simulation-to-reality transfer.
- Lab: integrate limbs into the lower-body assembly and perform supported tests.
- Assignment: train and evaluate a locomotion policy using a scaffolded simulation environment.
- Lectures: Skill representations and sequencing; Integrated robot behavior.
- Lab: complete system integration and present team demonstrations.
- Assignment: implement a simple skill-sequencing task in simulation and submit a brief technical report documenting hardware and software results.
Participation and the final demonstration
Activities include four weekly assignments, laboratory participation, and a final team demonstration and report. Instructors give feedback on understanding, testing, and documentation. The course is non-credit, with no formal grade. Untethered walking and manipulation are stretch goals, and the simulation-based work keeps everyone learning when the hardware needs troubleshooting.
Lectures
- Motor fundamentalsComing soon · 5 Jan 2027
- Transmissions, encoders, and feedback controlComing soon · 7 Jan 2027
- Robot modeling and forward kinematicsComing soon · 12 Jan 2027
- Inverse kinematics and trajectory generationComing soon · 14 Jan 2027
- Reinforcement learning for locomotionComing soon · 19 Jan 2027
- Simulation-to-reality transferComing soon · 21 Jan 2027
- Skill representations and sequencingComing soon · 26 Jan 2027
- Integrated robot behaviorComing soon · 28 Jan 2027
@online{zandonati2027metalhumanoid,
  author    = {Ben Zandonati and Willie McClinton and Seth Robles and James Kim},
  title     = {Metal2Humanoid},
  year      = {2027},
  month     = {jan},
  url       = {https://benzandonati.co.uk/notes/courses/metal2humanoid/},
  urldate   = {2026-11-05},
  note      = {Online; accessed 2026-11-05},
  keywords  = {humanoids, robotics, course},
}Ben Zandonati, Willie McClinton, Seth Robles and James Kim (2027). Metal2Humanoid. Retrieved from https://benzandonati.co.uk/notes/courses/metal2humanoid/
Discussion